Fair point, mine just goes vroom.
Next project up is a my take on a UROV (underwater remotely operated vehicle) that I am calling “The Marlin” (or at least until I come up with a better name)
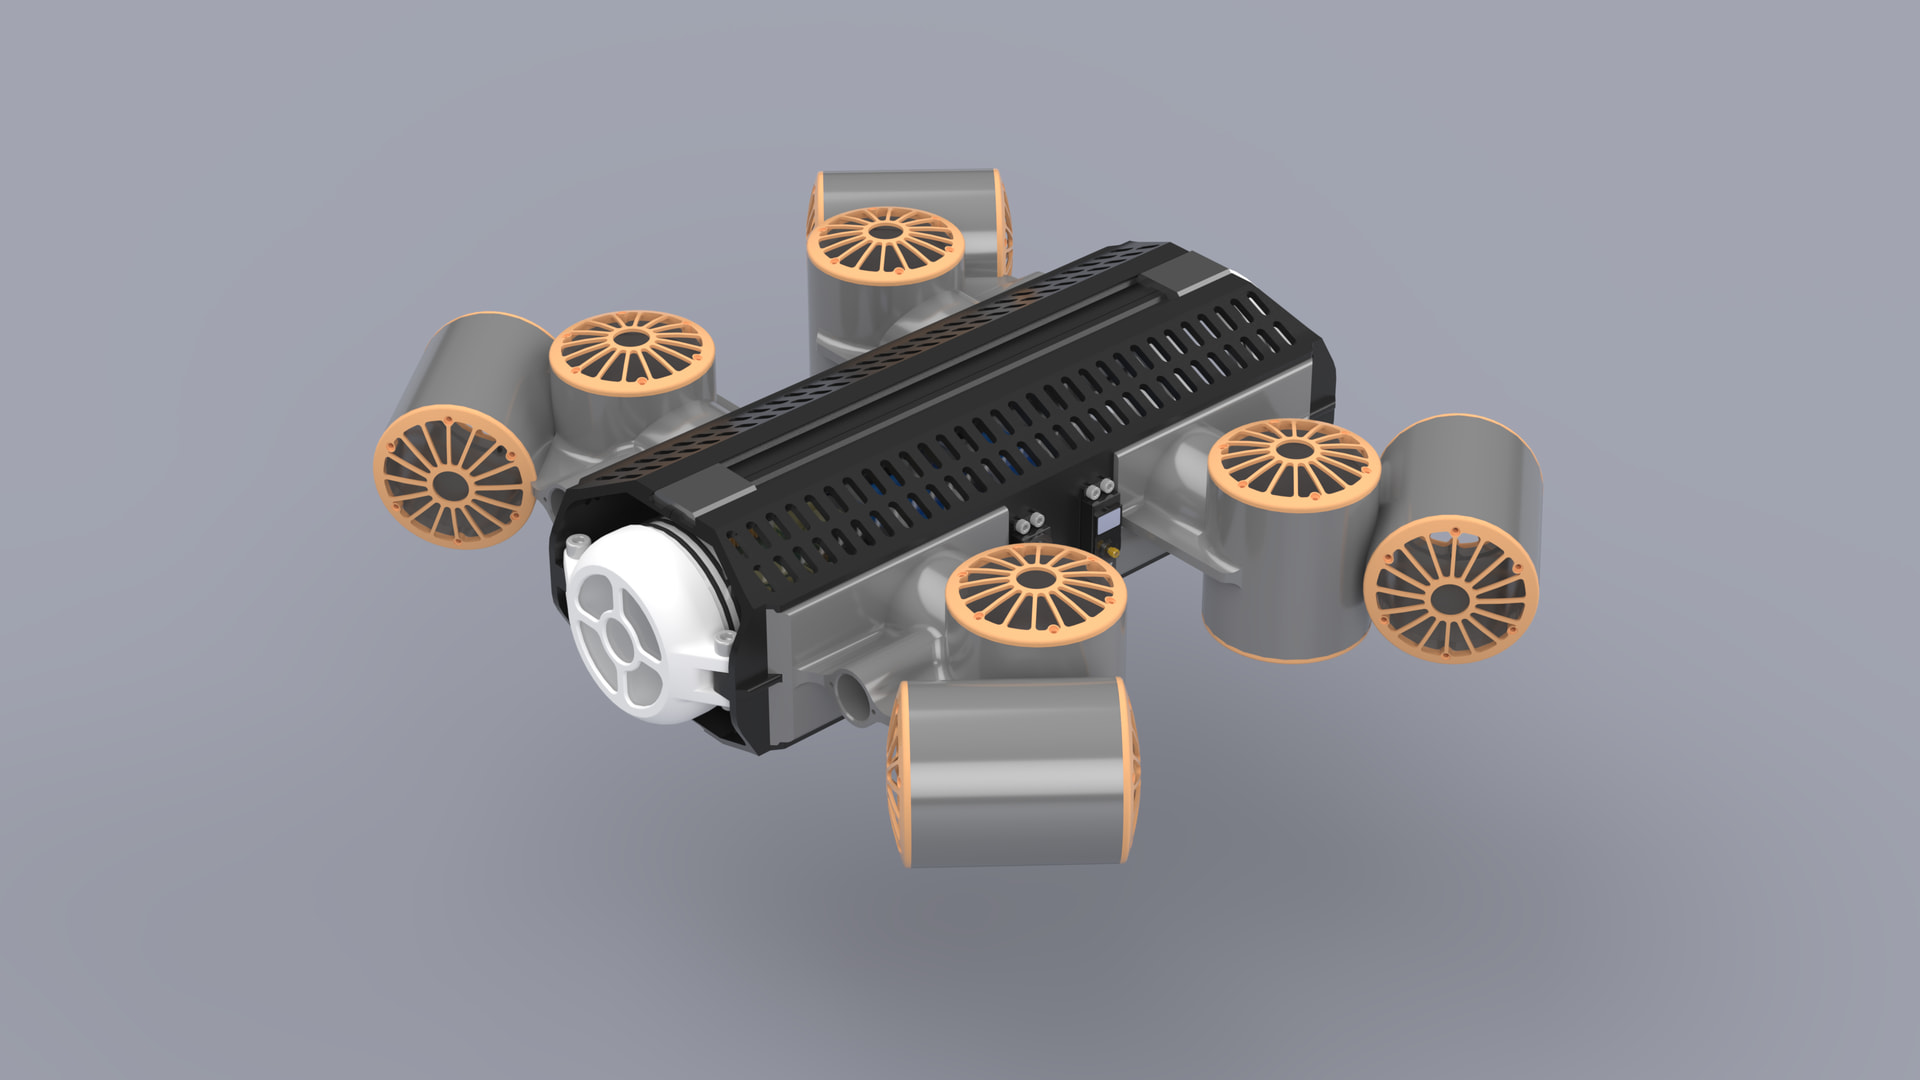
I am building it around a 150mm diameter by 600mm length Acrylic pipe, so I have enough room to fit in all the needed electronics.
So far I have tested my pressure vessel in a hot tub, but there will definitely need to be some modifications to make it more fitting for deep sea. I am aiming for capabilities around 40 meters / 130 feet depths because that it my legal limit to my Scuba certifications. And if I want to go deeper, I would most likely have to switch over to using an aluminum pipe as the pressure vessel.
My first version is going to be similar to the one above with 8 motors that will give me 6 degrees of freedom for maneuverability.

I am going with this setup because it will allow for the best control and with more motors you can run them at lower RPM so that less turbulence is created. (important for not kicking up sand/dirt and ruining visibility).
The great part about this is ArduSub ecosystem since it is well tested and includes a considerable amount of documentation. Although it is slightly outdated at this point.
All the “brains” are focused around a Raspberry Pi 4b and a Pixhawk flight controller. Turns out the Pi 5s will run a little too hot to be in an enclosed space.
All powered using 3 3s2p 18650 based battery packs, which should give me a run time around 2 hours. Depending on how that works out, I might switch over to 21700 cells to give me a little more run time. But I also need to consider the weight distribution and buoyancy calculations and the batteries are the heaviest parts. I am going to wait until more components arrive so I can more accurately calculate the CG and Buoyancy in SW.
My original budget was to keep it somewhere around 1500 USD. The problem that I am running into is finding an imaging sonar that doesn’t hurt my wallet too much.
We’ll see how it goes, this one is going to get pricey.
Unnecessary 4k Render:
A few finishing touches before I start printing out the parts.
Mostly just added in a few of the goodies like the carry handle, landing legs, and the grabber arm.
The nice thing is that I designed each side of the rails with a mounting system so I can add on to it as needed. I still need to make a GoPro mount and add a guide for the tether/Cat6 cable.
The next big design step is to wait for the motors to show up so I can accurately model in mounts for them and run some CFD simulations on a few different propellor designs.
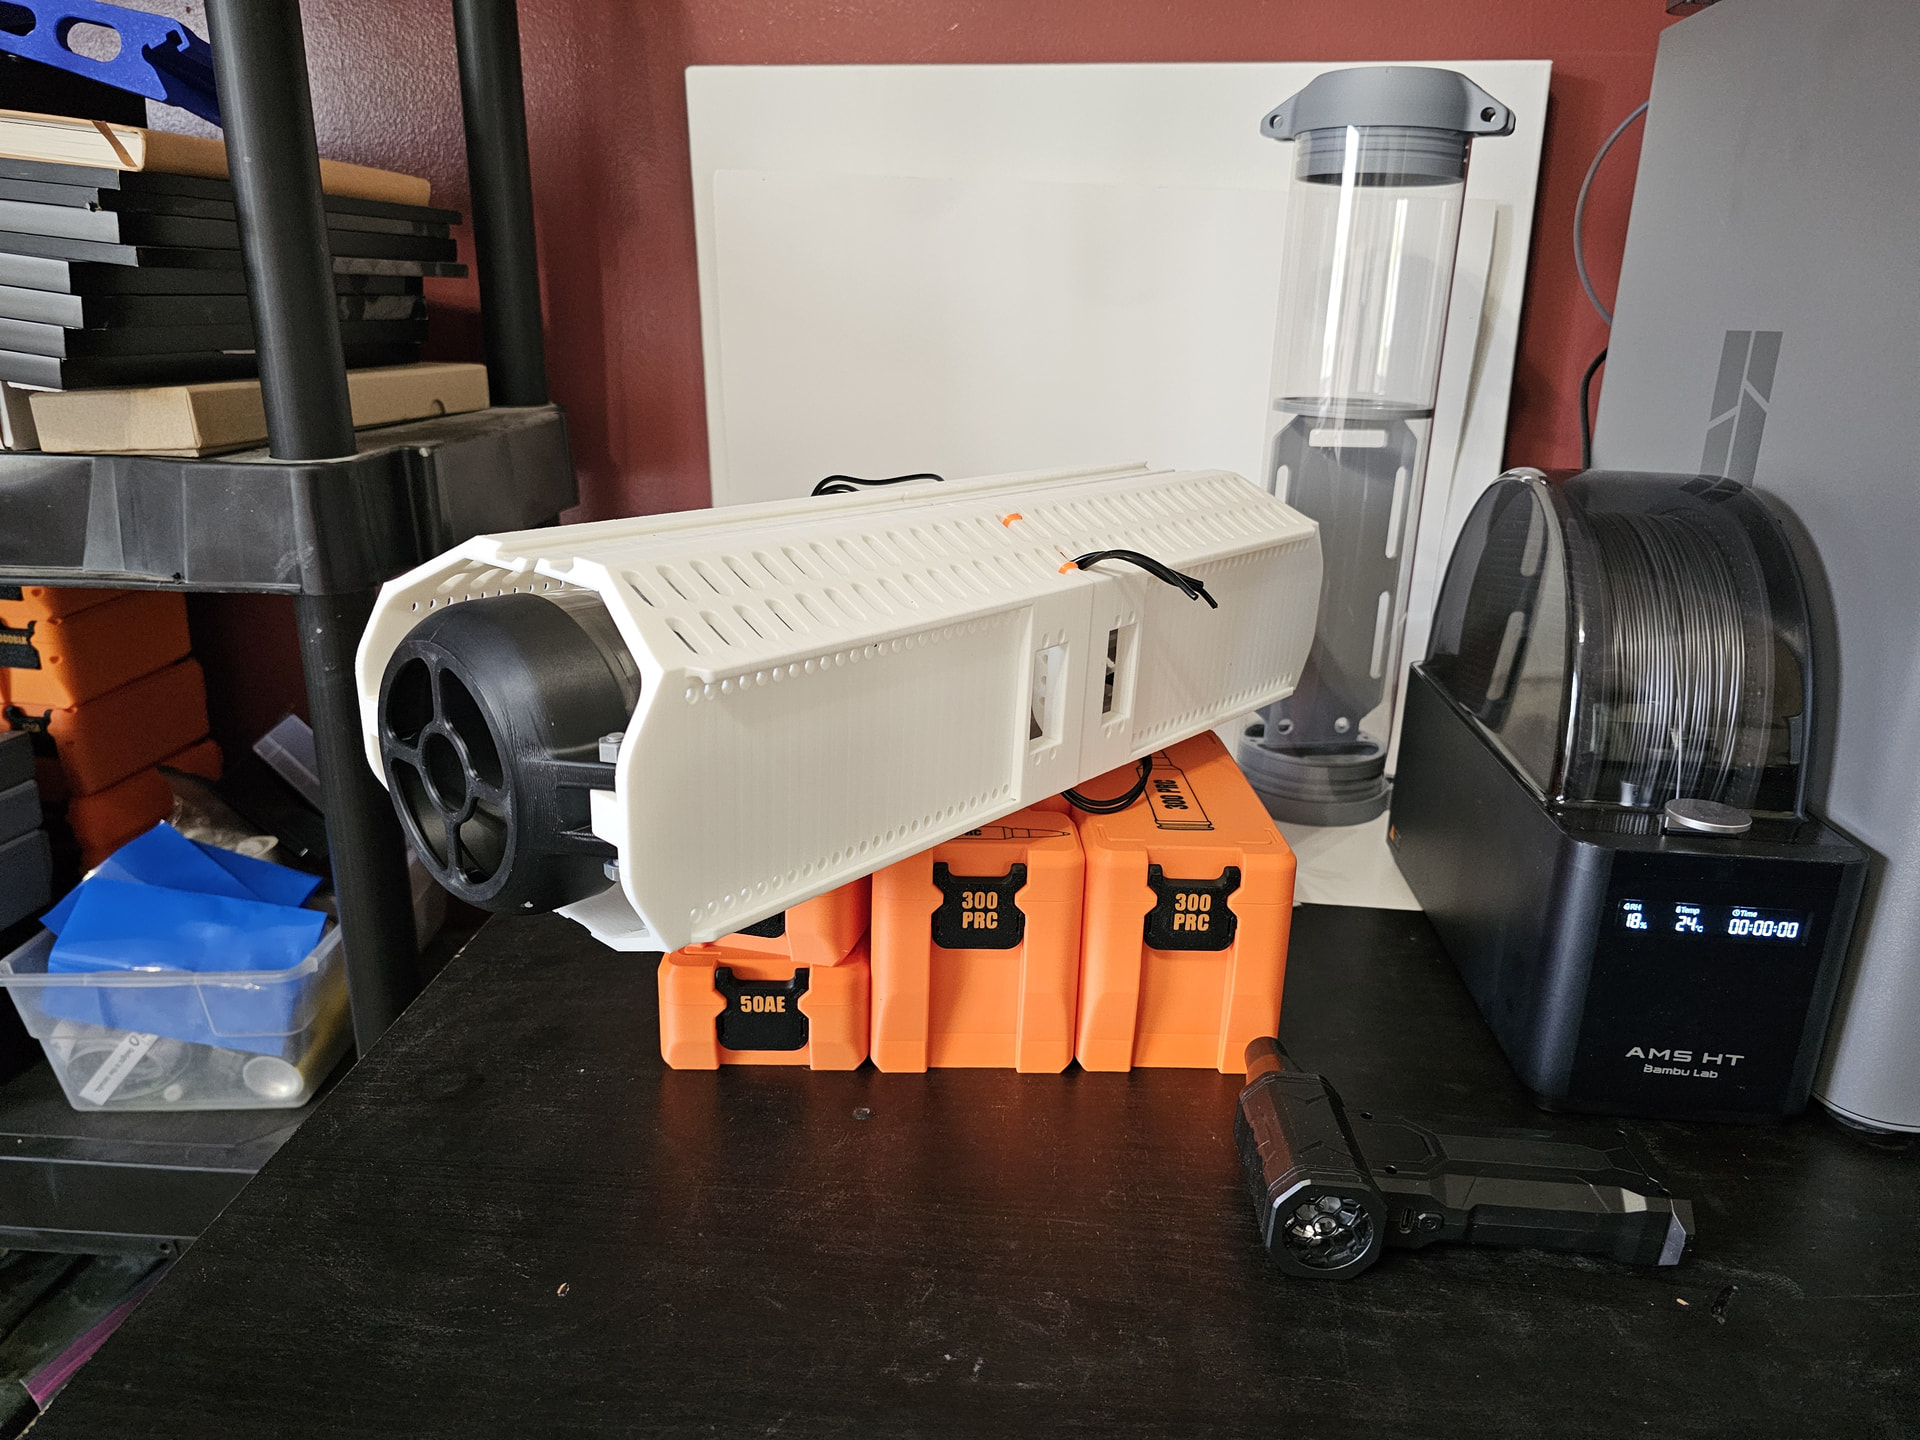
Well, almost a month later everything is starting to come together.
I’ve been redesigning a lot of stuff, but finally got to a solution I liked. Turns out my original water proofing was not good for any more than 20 feet, so had to scrap that and buy some thicker acrylic and use 3 O rings on each side instead of only 2. Greasing the O rings helped a lot to get a good result, without that it was pinching them leading to leaks.